
Master’s thesis / Planned
Datasheet-grounded review of KiCad schematics
I am developing a local system to review component-specific schematic faults using manufacturer datasheet.
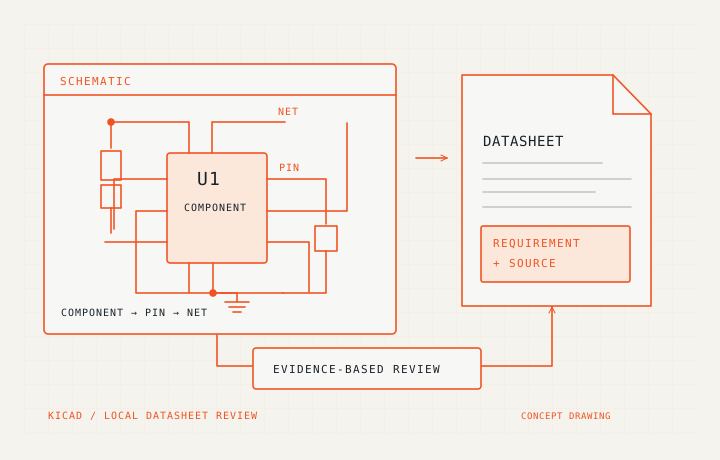
The research direction
In my master’s thesis I am investigating the use of a local, datasheet-assisted approach to reviewing component-specific faults in KiCad schematics beyond conventional electrical rule checking.
The work will connect the structure of a schematic with manufacturer datasheet. I will develop the local system and compare the review approaches.
The review workflow
I will design a workflow that combines four elements:
- Component–pin–net relationships will represent how the parts of a schematic are connected.
- Manufacturer datasheet evidence will inform component-specific review.
- Deterministic checks will support rule-based review.
- A local language model will form part of the review approach.
I will aim to review schematic faults with evidence tied to the relevant component and connection.
How it will be evaluated
I will define an evaluation protocol comparing rule-based, model-based, retrieval-assisted and hybrid approaches. The comparison will examine several aspects of review quality:
- Fault detection: whether an approach identifies the faults under evaluation.
- Localization: whether a reported issue points to the relevant part of the schematic.
- False warnings: whether an approach reports issues that are not faults.
- Evidence quality: whether the review provides suitable supporting evidence.
Planned stages
I will define the review workflow and evaluation protocol, develop the local system and carry out the comparison during my thesis, planned for September 2026 to January 2027.